
|
|
|
|
|
|


Additionally, there are several options to choose from, enabling customization to suit a dataset with a particular set of variables or needs. Template, Pipeline, Image scale, Keypoints, Internals confidence, and Automatic Intersection Tie points are available for adjustment in this important step and can be utilized to improve calibration where applicable. This article will define each to inform of its function and help aid selection when needed.
IN THIS ARTICLE
Calibration
Processing template
Calibration
Template
Pipeline
Image scale
Rematch type
More options
Keypoints
Internals confidence
External confidence
Pipeline strategy
Automatic ITPs
Compute relative confidence
Vertex conversion
General matching strategy
Image pairs matching strategy
Image pairs matching strategy
Reoptimization
Calibration
Processing template
- Nadir - Template for aerial images captured at the nadir perspective (up to 20º off nadir)
- Oblique - Template for images captured with an angle of more than 20º off nadir
- PIX4Dcatch - Template for projects captured with PIX4Dcatch
Note: The Oblique processing template is now automatically selected when a project is detected as an oblique dataset (i.e., more than half the images have a nadir angle over 20 degrees)
Calibration
During the Calibration step, the images and additional inputs, such as GCPs, will be used to perform the following tasks:
- Keypoints extraction: Identify specific features as keypoints in the images.
- Keypoints matching: Find which images have the same keypoints and match them.
- Camera model optimization: Calibrate the internal (focal length) and external parameters (location and orientation) of the camera.
- Geolocation GPS/GCP: Locate the model if geolocation information is provided.
Automatic Tie Points are created during this step and are the foundation for the next steps of processing.
Template
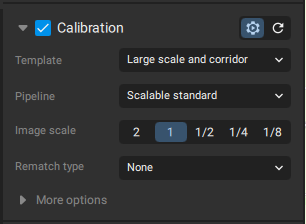
A Template is a general set of predefined settings to handle a particular type of dataset. Select the template that the dataset matches the most, a matching pipeline for the selected template will also populate the appropriate field.
The following templates are available for selection:
| Template | Name | General characteristics |
| Large scale and corridor | Generate 2D and 3D reconstructions of large project areas with aerial imagery from both nadir and less oblique perspectives to include a mix of both perspectives. This is the default template and was designed to handle a majority of datasets efficiently and quickly. | Default pipeline: Scalable Standard. Recommended Input: Nadir imagery. |
|
Flat scene and low texture |
Generate 2D and 3D reconstructions of subject matter containing relatively homogenous textures and flat terrain. Images should be captured above the area of interest and are best from the nadir perspective. This template was designed for agricultural applications. | Default pipeline: Low texture planar. Recommended Input: Nadir imagery. |
| Note: The Flat scene and low texture template should not be used with oblique images. | ||
|
Map |
Generate 2D and 3D reconstructions of a project using aerial images. This template is similar to Large scale and corridor, but optimized for medium and small-scale areas of interest. | Default pipeline: Standard. Recommended Inputt: Nadir imagery. Processing Speed: Slower. |
| Tip: For projects with 1000 images or less, it is recommended to process with the Map template instead of the Large scale and corridor. | ||
| Model | Generate 3D reconstructions of objects with oblique images. This template was designed to address the specific needs for reconstructing objects. | Default pipeline: Standard. Recommended Input: Oblique imagery. Processing Speed: Slower. |
| PIX4Dcatch | Generate 2D and 3D reconstructions of an area or object of interest. This template was designed to optimize the processing of PIX4Dcatch datasets, to include specific options created just for PIX4Dcatch projects.
For more information: How to process PIX4Dcatch datasets in PIX4Dmatic. |
Default pipeline: Trusted location and orientation. Recommended Input: Terrestrial imagery. Processing Speed: Faster. |
| Interior scene | For interior projects captured with the PIX4Dcatch mobile application and calibrated with ITPs. | Default pipeline: Trusted location and orientation. Recommended Input: Terrestrial interior imagery. Processing Speed: Faster. |
| No GPS | For projects where the images do not contain geolocation and orientation values. |
Template: No GPS |
Pipeline
Pipeline defines how the camera's internal and external parameters are optimized.
- Scalable standard (default): This calibration pipeline is a sequential pipeline that enhances image calibration for large datasets and fast processing.
- Standard: This calibration pipeline is similar to Scalable Standard, but it is more robust, requires more processing time, and uses more PC resources.
- Low texture planar: The calibration pipeline is intended for aerial nadir images with accurate geolocation and homogeneous or repetitive content of relatively flat terrain.
- Trusted location and orientation: This calibration pipeline is intended for projects with accurate relative location and IMU data. For example, images taken with PIX4Dcatch in an indoor or outdoor setting or images from RTK or PPK drones or devices. All images must include information about the camera's initial position and orientation.
Image scale
Defines the image size at which keypoints are extracted. It is possible to select:
- 2 (Double image size): Image scale for interior scene calibration template. Image scale automatically selected for thermal images.
- 1 (Original image scale): This is the recommended Image scale.
- 1/2 (Half image scale): This can be used to speed up processing and for cameras with very high resolution.
- 1/4 (Quarter image scale): This can be used to speed up processing to get a fast overview and assess the completeness of the project.
- 1/8 (Eighth image scale): This can be used to speed up processing to get a fast overview and assess the completeness of the project.
- To speed up processing.
- To get a fast overview and to assess the completeness of the project.
- For datasets containing blurry images.
- When processing datasets of flat and homogenous or repetitive and complex areas, such as trees, forests, and fields, because it can result in a higher number of calibrated images.
Rematch type
Replaces the previous “Rematch” on/off switch. It controls whether more matches between images are computed after the first part of the calibration.
- None: No rematching.
- Default: After the first part of the calibration, adds more matches between images, keeping only those that agree closely with the current 3D model of the scene. Intended for easy projects.
- Robust: After the first part of the calibration, adds more matches between images, also keeping those that agree only loosely with the current 3D model of the scene, so that errors in the model can be corrected. Intended for difficult projects.
- Auto: Automatically chooses the rematch type to use.
More options
Keypoints
Control the number of extracted keypoints.
- Auto (default): PIX4Dmatic automatically determines the optimal number of keypoints to extract.
- Custom: Directs PIX4Dmatic to identify a specific number of keypoints, image content permitting.
- Number of Keypoints: The targeted number of keypoints to be extracted per image.
Internals confidence
Defines how much the camera's internal parameters can be recalculated and adjusted during the project calibration:
- Low (default): Optimizes all internal camera parameters. This is recommended for cameras that are not included in the database or whose internal parameters require more precise adjustment.
-
High: Forces the internal parameters to remain close to their initial values. Depending on the circumstances, it is generally recommended to use this setting only when both of the following conditions are met:
- The camera is already included in the database (providing more reliable initial values).
- The scene geometry is such that it cannot properly constrain the internal parameters (e.g., nadir-only flights over flat terrain).
- Absolute: The initial parameters are fixed and excluded from the optimization process .
 Allows simultaneous camera internals and MTP/GCP optimization.
When enabled, camera internals are optimized simultaneously with manual tie points (MTPs) and ground control points (GCPs). When disabled, camera internals are not optimized while optimizing MTPs and GCPs.
In most cases, this setting does not require manual adjustment, as it is automatically enabled or disabled based on the selected processing template. For example, it is disabled by default when using the PIX4Dcatch template.
However, disabling this option can be helpful in projects where conflicting positional data is present. This situation can arise when combining high-precision RTK/PPK imagery that contains outliers with GCPs. Although both the camera positions and GCPs may report high accuracy, conflicts can occur when one of the data sources is less accurate than assumed. These conflicts may cause the optimization process to over-adjust the internal camera parameters in an attempt to align the model with the GCPs. As a result, the model's quality may be significantly diminished, leaving many cameras uncalibrated or causing the calibration process to fail completely
Note: This option is unavailable when internal confidence is set to Absolute.
External confidence
Defines how much the camera's external parameters can be recalculated and adjusted during the project calibration:
- Standard. Allows the camera positions and orientations based on the accuracy of the camera table. It can be used by default; low accuracy can negatively impact the final alignment.
- Absolute. Do not optimize external parameters. Only available with the “Trusted location and orientation” pipeline.
Starting in PIX4Dmatic 2.13, the former Low and Auto options have been removed. Their behavior is now covered by Pipeline strategy and General matching strategy
- Low. Optimizes camera position and orientation when geolocation and orientation data are not very accurate. Processing is slightly slower but more robust.
- Auto. Selected automatically by PIX4Dmatic after importing the images.
Pipeline strategy
- Default: Standard processing, recommended for accurate geotags.
- Robust: For inaccurate geotags or hard-to-match images.
- Auto: Automatically chooses the pipeline strategy to use.
Robust and Auto are only available with the “Trusted location and orientation” pipeline. If you switch to another pipeline, the setting goes back to Default.
Use depth maps (PIX4Dcatch LiDAR datasets)
Use depth maps are available and activated by default for projects captured with LiDAR depth data, and can be toggled off if desired. When enabled, the depth maps generated with PIX4Dcatch are used for better calibration.
For more information: How to process PIX4Dcatch datasets in PIX4Dmatic.
Automatic ITPs (Optional)
Toggle on to generate and match structural lines and intersections between images. The default is set to off, however, when enabled ITPs can be used to help calibrate a scene with man-made structural elements.
For more information: Intersection Tie Points - PIX4Dmatic.
Compute relative confidence
Toggle on to compute the relative confidence of the generated ATPs and enable color by confidence. The default is set to off. This setting will have an impact on the processing time.
Vertex conversion
Toggle on to use marked geometry vertices to improve the Calibration. The default is set to off. This feature is related to the Vertex Tie points. For more information: Tie Points (GCPs, MTPs, and CPs) - PIX4Dmatic
General matching strategy
- Standard: Uses all matches found. Faster but less robust.
- Geometrically verified: Matches that are not geometrically consistent are discarded. Slower but more robust. This is the only option with the “Low texture planar” pipeline.
- Auto: Chooses between Standard and Geometrically verified depending on how accurate the image geotags are. Only available with the “PIX4Dcatch” and “Interior scene” templates combined with the “Trusted location and orientation” pipeline.
Image pairs matching strategy
Image pairs matching strategy
- Use capture time (on/off, with Number of neighboring images): Maximum number of subsequent images in time to match.
- Match nearest neighbors (on/off): Match pairs found by triangulating the GPS positions.
- Match all images within distance (on/off, with the distance value): Matches all images within a maximum distance, given as a multiple of the median distance between cameras.
- Use time for multiple cameras (on/off, with a number of images): Matches images taken around the same time by different camera models.
- Use tie points (on/off, with a maximum number of image pairs per tie point): Maximum number of pairs connected by MTPs, mITPs, VTPs and GCPs to match
- Use ground overlap matching for terrestrial images (on/off): Match pairs of cameras with field of view overlapping on ground plane
- Use pre-matching (on/off): Preprocess all image pairs by matching them coarsely to select overlapping pairs. Recommended for datasets without GPS tags.
“Match nearest neighbors”, “Match all images within distance” and “Use ground overlap matching” are disabled if some cameras have no location or orientation data.
Reoptimization
- In the menu bar, click Process > Calibration... > Reoptimization
- Or select the Reoptimization button
 after enabling the Calibration step and click Start.
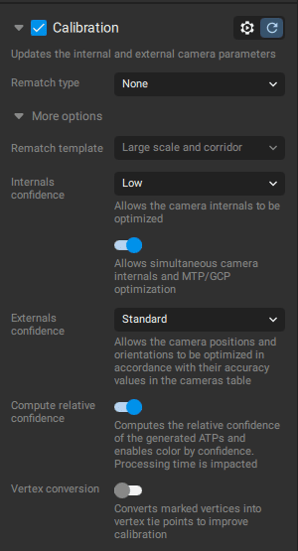
This process is used to reoptimize already computed internal and external camera parameters. It can be used when changes to GCPs are applied after the Calibration step is completed.
- Rematch type. Options are None and Default. This setting is only available if image features were saved during calibration, meaning Calibration was run in “Full processing” mode. Otherwise it is set to None. The rematch template is only applied when the rematch type is not None.
- Rematch template. Rematch runs after the first part of the calibration. It uses the calibrated camera positions and the current 3D model to find new image pairs and add matches between images that are already calibrated, then optimizes the calibration again. It strengthens the reconstruction when the first matching found too few connections, such as with poor or missing GPS, flat low-texture scenes or mixed flights, and costs extra processing time.
- Internal confidence
- External confidence
- Toggle on Compute relative confidence to compute the relative confidence of the generated ATPs and enable color by confidence. The default is set to off. This setting will have an impact on the processing time.
- Toggle on Vertex conversion to use marked geometry vertices to improve the Calibration.
Such changes can be:
- Adding GCPs marks.
- Changing the position of existing GCPs marks.
- Removing GCPs with marks.